SIM001 › Beyond the cockpit › Flying by plan
Sending plans
An agent plan tells the plane what to do for the next few seconds. It has a primitive, a target or a point, a plan id and a time to live. The ground sends it as a MAVLink COMMAND_INT with the command 31010 (MAV_CMD_USER_1). param1 is the primitive, param2 the target, param3 the plan id and param4 the time to live in seconds.
x and y are the latitude and the longitude of the point, in 1e-7 degrees. z holds two numbers: the altitude above home, to 0.25 m, and the radius, to 1 m. Encode z as round((altitude + 512) × 4) × 1024 + round(radius). The altitude can be from -512 m to 511.75 m, and the radius from 0 m to 1023 m. The encoder clamps a value outside its range. In Rust, cognition_plan::WirePlan::to_command does this.
The plane answers each plan with a COMMAND_ACK. If the plane refuses the plan, the reason is in result_param2: 1 if the plane is not in AGENT mode, 2 if the plan is malformed, 3 if the plane has no home yet, and 4 if the plane has no executor.
The ground sends a new plan about once a second, with a new plan id each time. The plane flies the newest plan. If no new plan comes before the time to live ends, the plane circles where it is. Thus a plane that loses the ground does not fly away.
In AGENT mode, the plane sends its agent status, four NAMED_VALUE_INT messages, once a second. AG_PLAN is the id of its plan. AG_PRIM is the primitive of that plan. AG_ENV counts the steps where the safety envelope changed what the plan asked for. AG_FALL tells you if the plane stopped the plan, and why.
AGENT mode takes a go-to plan
If the flight mode of the plane is AGENT, type plan goto 80 10 40 0 600 in the console. This plan tells the plane to fly to the point 80 m north and 10 m east of home, at 40 m. The plane replies with COMMAND_ACK, result 0 (ACCEPTED). The console shows ack with result=0. AG_PLAN goes up by 1, to the id of the new plan (plan= in the console). AG_PRIM is 3, go to (prim=3). The plan is good for 600 s.
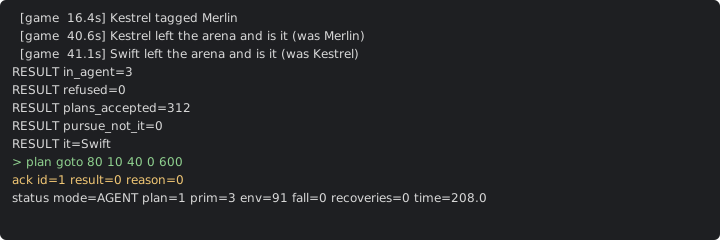
See it in Watching a game of tag by plan, Sending your first plan, Letting a plan run out.
How this is tested verified
Given the flight mode of the plane is AGENT
When the ground sends a go-to plan
Then the reply to the plan is accepted
  And the reported plan goes up by 1
  And the reported primitive is go to
  And the time to live of the plan is 600 s
A plan is refused outside AGENT mode
The plane takes plans only in AGENT mode. In FBWA, or in any other mode, the pilot or ArduPilot flies the plane. Switch to AGENT first. Then send the plan.
If the flight mode of the plane is FBWA, type plan goto 80 10 40 0 600 in the console. This plan tells the plane to fly to the point 80 m north and 10 m east of home, at 40 m. The plane replies with COMMAND_ACK, result 2 (DENIED) and the reason 1. The console shows ack with result=2 reason=1. AG_PLAN does not change.
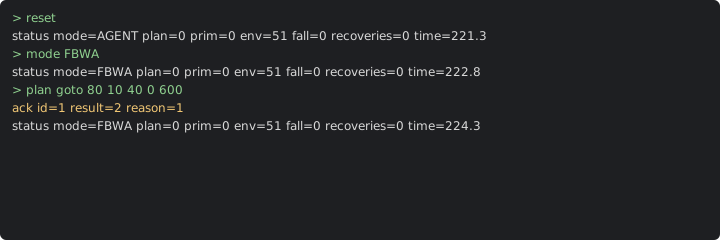
See it in Sending your first plan.
How this is tested verified
Given the flight mode of the plane is FBWA
When the ground sends a go-to plan
Then the reply to the plan is refused for the mode
  And the reported plan stays the same
A malformed plan is refused with a reason
The plane checks each field of the plan. A primitive that does not exist, a number that is not finite or a point off the globe makes the plan malformed. The plane keeps the plan that it flies.
If the flight mode of the plane is AGENT, type plan 9 80 10 40 0 600 in the console. There is no primitive 9. The plane replies with COMMAND_ACK, result 2 (DENIED) and the reason 2. The console shows ack with result=2 reason=2. AG_PLAN does not change.
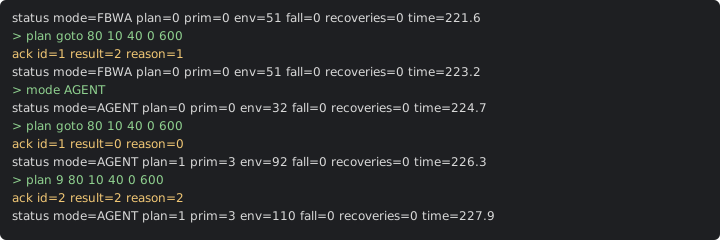
See it in Sending your first plan.
How this is tested verified
Given the flight mode of the plane is AGENT
When the ground sends a malformed plan
Then the reply to the plan is refused as malformed
  And the reported plan stays the same
AGENT mode starts with no plan
In AGENT mode, the plane forgets the old plan and the old count of AG_ENV. It flies wings level and holds its height until a plan comes.
If the flight mode of the plane is FBWA, switch the plane to AGENT: type mode AGENT in the console. AG_PLAN is 0, and the console shows plan=0. AG_PRIM is 0 (prim=0).
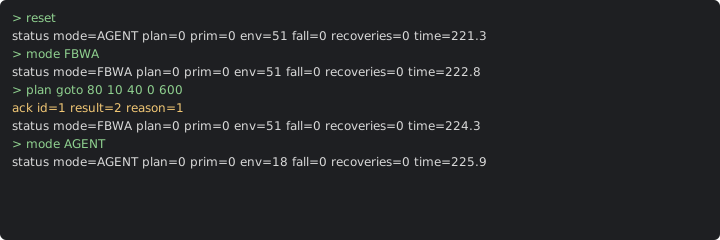
See it in Sending your first plan.
How this is tested verified
Given the flight mode of the plane is FBWA
When the flight mode of the plane is AGENT
Then the reported plan is 0
  And the reported primitive is none
A new plan id replaces the plan
The plane does not finish the old plan first. It turns to the new plan at once.
If the reported primitive is go to, type plan orbit 70 0 45 45 600 in the console. This plan tells the plane to circle the arena centre at 45 m from it, at 45 m. AG_PLAN goes up by 1, to the id of the new plan (plan= in the console). AG_PRIM is 4, orbit (prim=4).
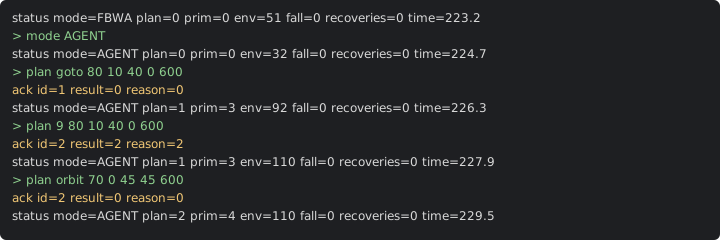
See it in Sending your first plan.
How this is tested verified
Given the reported primitive is go to
When the ground sends an orbit plan
Then the reported plan goes up by 1
  And the reported primitive is orbit
A repeated plan id changes nothing
The plane flies a plan id only once. If a plan comes again with the same id, the plane keeps the plan that it has, even if the new message has another primitive. Thus a plan that the link sends twice does not restart.
The rule below is what the plane must do. It does not do it yet. The plane flies the first plan, but AG_PRIM shows the primitive of the new message (prim=4). Until this is repaired, do not use AG_PRIM to see what the plane flies after a repeated plan id.
If the reported primitive is go to, type again orbit 70 0 45 45 600 in the console. This sends an orbit plan with the id of the last plan. The plane replies with COMMAND_ACK, result 0 (ACCEPTED). The console shows ack with result=0. AG_PLAN does not change. AG_PRIM is 3, go to (prim=3).
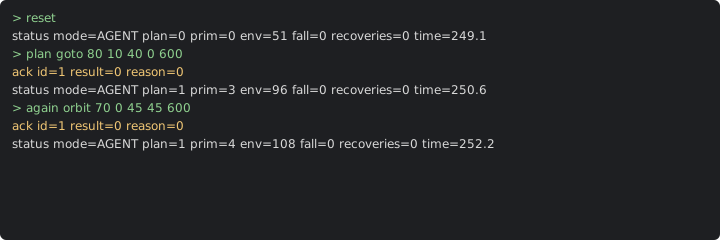
How this is tested failed
Given the reported primitive is go to
When the ground sends the plan id again with an orbit
Then the reply to the plan is accepted
  And the reported plan stays the same
  And the reported primitive is go to
A plan that runs out makes the plane circle
If the time to live of the plan ends before a new plan comes, the plane circles where it is. It tells the ground why, with AG_FALL and the message "Agent: fallback 1". A short recovery can also show, as recoveries in the console. To give each plan more time, set AGENT_GRACE. It is in seconds, and it is 0 by default.
If the time to live of the plan is 5 s, type wait 10 in the console. AG_FALL is 1 (fall=1), and the plane circles where it is.
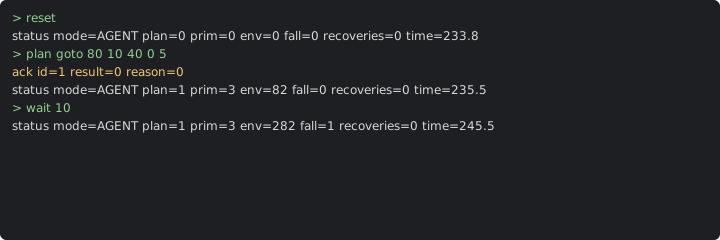
See it in Letting a plan run out.
How this is tested verified
Given the time to live of the plan is 5 s
When the plane flies on for 10 seconds
Then the reported fallback is plan expired
A new plan ends the circle
The plane flies the new plan at once. With the parameters of ardupilot/t1s.parm, a short recovery can show in AG_FALL as 3 at the same time.
If the time to live of the plan is 5 s, type plan goto 80 10 40 0 600 in the console. This plan tells the plane to fly to the point 80 m north and 10 m east of home, at 40 m. The reported fallback is none or recovery.
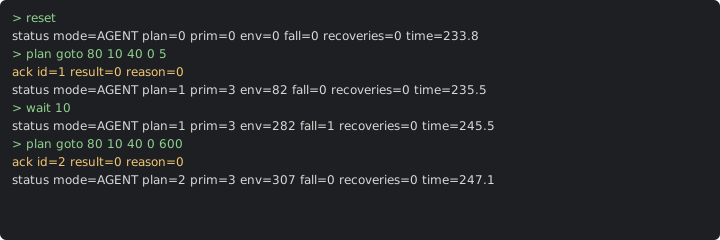
See it in Letting a plan run out.
How this is tested verified
Given the time to live of the plan is 5 s
When the ground sends a go-to plan
Then the reported fallback is none or recovery
The plane reports its plan once a second
The plane sends AG_PLAN, AG_PRIM, AG_ENV and AG_FALL once a second while it is in AGENT mode. Count the AG_PLAN messages to see that the plane is alive.
If the flight mode of the plane is AGENT, type watch 10 in the console. The console counts the AG_PLAN messages in the next 10 s of simulated time. The console shows reports 10, or 9 or 11: the status comes once a second.
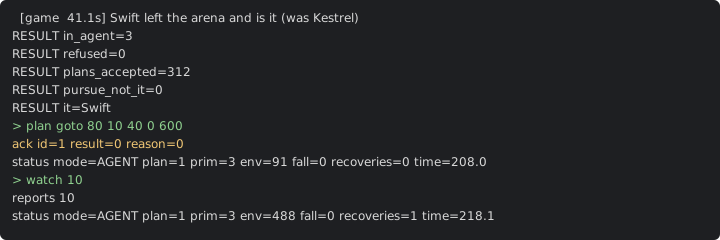
See it in Watching a game of tag by plan.
How this is tested verified
Given the flight mode of the plane is AGENT
When the operator watches the status for 10 seconds
Then the status reports in 10 seconds are between 9 and 11